
How to Select an Integral Gearmotor Using KEB-Drive
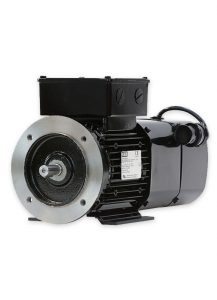
A practical walkthrough of gearmotor fundamentals and the nine-step selection logic behind KEB’s configuration tool.
Specifying a gearmotor is a systems decision, not a catalog lookup. The gear type, motor, ratio, mounting, and accessories all interact, and a change to any one of them can shift the others. KEB-Drive (app.keb-drive.de) is built around that reality. Rather than presenting a flat parts list, it walks the user through nine sequential decisions, starting with the gearing family and ending with the mounting orientation the unit ships in. This article covers the basics of what an integral gearmotor is, the criteria that drive a correct selection, and how that logic maps onto the KEB-Drive interface, step by step.

What Is an Integral Gearmotor?
An integral gearmotor combines a gear reducer and an electric motor into a single mechanical assembly, sharing one housing, one set of output bearings, and one lubrication system. This is different from a separately coupled reducer and motor, where the two components are aligned, coupled, and maintained independently. Integrating the two removes a coupling, a second footprint, and a second set of alignment tolerances, which is why integral gearmotors dominate general industrial automation, material handling, and packaging applications.
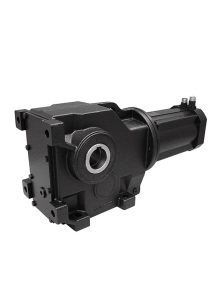
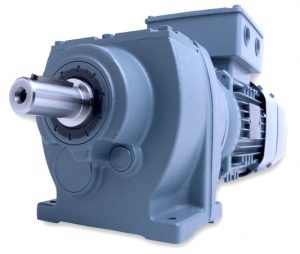
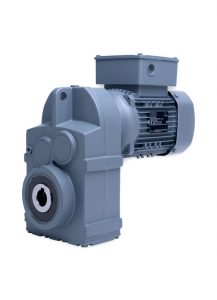
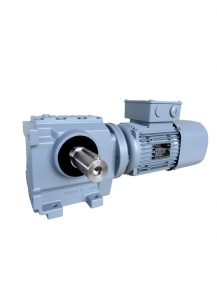
KEB offers four gear technologies, each suited to a different output orientation and duty profile:
● Helical inline (G series), inline output, 94 to 96 percent efficiency
● Helical parallel offset (F series), parallel offset output, 94 to 96 percent efficiency, useful when the input and output shafts need to run alongside each other rather than through one axis
● Helical bevel (K series), right-angle output, 94 to 96 percent efficiency
● Helical worm (S series), right-angle output, 50 to 90 percent efficiency, generally more cost-effective at high reduction ratios but less efficient than the bevel alternative

Across these families, KEB’s standard modular system covers gear ratios up to roughly 500 900 to 1 (double gearbox) and output torques from about 60 Nm up to 13,60016,000 Nm, with three-phase motors from 0.12 kW to 45 kW and servo motors layered on top for closed-loop applications. That range is wide enough that the real work of selection is narrowing it to the handful of combinations that actually satisfy the application.
Start With the Application, Not the Tool
Before opening KEB-Drive, it pays to have answers to a short list of questions, because every one of them changes which branch of the tool is relevant:
● What torque and speed are needed at the gearmotor output, and is that load steady or does it include shock loading (starts, jams, impacts)?
● What is the duty cycle, and how many hours per day and starts per hour will the drive see?
● Does the application need to hold a load at zero speed, such as a hoist or vertical axis?
● Is position or speed feedback required, or is open-loop control acceptable?
● How will the unit mount to the machine, and are there space, orientation, or shaft-interface constraints?
● What is the operating environment, including temperature range, washdown, or corrosive exposure?
The shock and duty answers matter more than they might seem to at first glance. KEB’s catalog ties gearbox sizing to an application factor (fB) derived from the shock grade of the driven machine, the operating hours per day, and the number of starts per hour, and the selection rule is that the gear coefficient of the chosen combination (cG) must be equal to or greater than that application factor, in addition to the output torque simply being high enough. A combination that clears the torque requirement but falls short on cG is still an undersized selection.

Step 1: Choose the Gear Type
KEB-Drive’s layout starts at the top left with the gear family and frame size, which is the natural entry point once the output orientation (inline, offset, or right angle) and rough torque class are known. This single choice sets the shape of everything downstream: an inline (G) or offset (F) unit keeps the drive train on one plane, while a bevel (K) or worm (S) unit turns the output 90 degrees, which is often the deciding factor in tight machine layouts before torque and speed are even considered.
This is also where the option to omit the gearbox entirely lives, for cases where only a standalone induction or servo motor is being specified.
Step 2: Select Motor Size and Winding Configuration
With the gear family set, KEB-Drive moves to motor size, winding, voltage, and frequency. KEB’s standard three-phase line spans 0.12 kW to 45 kW, and servo options are available where the application needs high dynamic response or tight positioning rather than constant-speed running. The default configuration for North America is a 60Hz winding that supports 230/460V connections. Other voltage options for 50Hz, 575V, and 208V are also available.

Step 3: Select Gear Ratio (Output Torque and Speed)
With the gear family and motor both fixed, the ratio choice is where torque and speed are dialed in. A higher ratio drops the output speed and raises the available torque; a lower ratio does the opposite. Because gearmotors combine a small number of standard motor speeds with a wide range of ratios, there are usually several ratios that land near the target output speed. KEB-Drive lists all of them so the comparison is direct, along with the resulting T2 (rated output torque), T2max (maximum continuous torque the gearbox can carry), and cG (gear coefficient) for each option.
This is the step where the application-factor homework from earlier pays off: confirming that cG meets or exceeds fB for the driven machine, not just that T2 clears the required torque, is what separates a correctly sized selection from an undersized one. If nothing in the list satisfies both checks, it is worth returning to Step 1 or Step 2 to try a different gear frame or motor size rather than accepting a marginal ratio.

Step 4: Select Mounting Configuration and Mechanical Options
With the drive train sized, the next fields define how the unit physically attaches to the machine. KEB’s standard mounting options include foot-mounted, flange-mounted, and combined foot-flange versions, along with several output shaft interfaces: a solid output shaft with a key, a hollow bore with a keyway, a hollow bore with a shrink disc for a zero-backlash, coupling-free connection to the driven shaft, and a splined hollow shaft. Where the gearbox and motor are supplied separately rather than as an integral unit, free input shaft and motor adapter options (IEC or servo-frame) are available instead.

This step also covers gearing-side mechanical options such as low-backlash gearing and protective covers, along with the choice between English and metric shaft and bore dimensions for equipment shipping to different regions.
Finally, this section also defines which lubricant type applies: mineral oil, synthetic PG, synthetic HC, or a food-grade synthetic.
Step 5: Select Electrical Options Including Brake and Encoder
A spring-set brake is the right call whenever the application must hold a load at zero speed, such as a vertical axis or a hoist, rather than relying on the motor alone. Once a brake is selected, additional options for a manual hand release and brake coil variants is listed.
Feedback and thermal options round out this step: incremental or absolute (multiturn) encoders for closed-loop position or speed control, forced ventilation for applications that run at low speed for extended periods under VFD control, and PTC thermistor or thermal relay protection for motor overtemperature monitoring.
Step 6: Select Additional IP Protection
Standard KEB gearmotors ship IP55, which covers general indoor industrial use. Applications with washdown, outdoor exposure, or corrosive atmospheres need more, and KEB-Drive lets that be specified directly rather than handled as a special request. Graduated corrosion protection packages (P1 through P3) step up paint and sealing to match increasingly severe environments, and a full IP65 washdown option is available with an enclosed motor design, epoxy-coated internal components, enhanced shaft seals, and a water-resistant terminal box cover for food and beverage, marine, and wastewater applications.
Step 7: Select Terminal Box Orientation
The conduit or terminal box orientation determines how the power and feedback cables enter and exit the unit relative to the machine frame. Getting this wrong is a common and entirely avoidable field problem: a terminal box that faces into a wall or an access panel forces a rework that has nothing to do with whether the gearmotor itself was sized correctly. KEB-Drive lets the orientation be set alongside the fitting location during configuration, so it shows up correctly on the dimensional drawing before the unit is ordered.
Step 8: Select Paint Options
Paint treatment covers both the number of coats and the color. Gray and black are standard and most commonly requested, but KEB can paint to a specified color on request. For harsher environments, paint thickness and system are tied to the IP protection level chosen in Step 6, so this step is worth revisiting if the environmental requirements changed earlier in the configuration.
Step 9: Select Mounting Orientation
The final step is the physical mounting position of the finished gearmotor, M1 through M6. This is not cosmetic. Mounting position determines how much lubricant the unit ships with and how it vents, since a gearbox mounted on its side or standing on end fills differently than one mounted flat. Setting mounting orientation correctly in the tool is what keeps the unit that ships matching the way it will actually be installed on the machine.

Full Documentation
After a configuration is made, additional tabs in KEB-Drive give a full text description of the selected gearmotor unit. Additional information like max torque and rated current ratings are displayed. Values like motor inertia and exact gear ratios are also given.
The dimensional tab gives options to download the integral gearmotor drawing as a PDF or a STEP 3D model.
Getting the Most From the Tool
KEB-Drive covers the combinations most machine builders need, but it is intentionally scoped to the commonly requested options. Absolute or safety-rated encoders, custom flanges and bores, and non-standard brake configurations for specialized applications are all available from KEB but are best worked out directly with a KEB gearmotor engineer rather than forced into the standard configurator fields. Used well, the tool turns gearmotor selection from a multi-catalog exercise into a single, nine-step decision path, which is exactly the problem it was designed to solve.

Related Articles

Let's Work Together
Connect with us today to learn more about our industrial automation solutions and how to commission them for your application.
"*" indicates required fields